Yue Chang | 常越
I am currently a first-year PhD student at The Hong Kong University of Science and Technology (Guangzhou), advised by Prof. Sihong Xie. I received my B.Eng. degree in Automation from Harbin Institute of Technology, Shenzhen.
Email / CV / GitHub / Google Scholar / Blog / WeChat
Education
The Hong Kong University of Science and Technology (Guangzhou) 2025.03 - now
PhD Student | Advisor: Prof. Sihong Xie
Harbin Institute of Technology, Shenzhen 2021.09 - 2025.07
B.Eng. in Automation
ResearchMy research focuses on spatiotemporal perception and memory for embodied intelligence, with a current emphasis on 3D scene graphs (3DSGs). I also work on vision-language navigation (VLN), 3D reconstruction, and multimodal LLM (MLLMs). |
| In the Year of 2026 | |
|
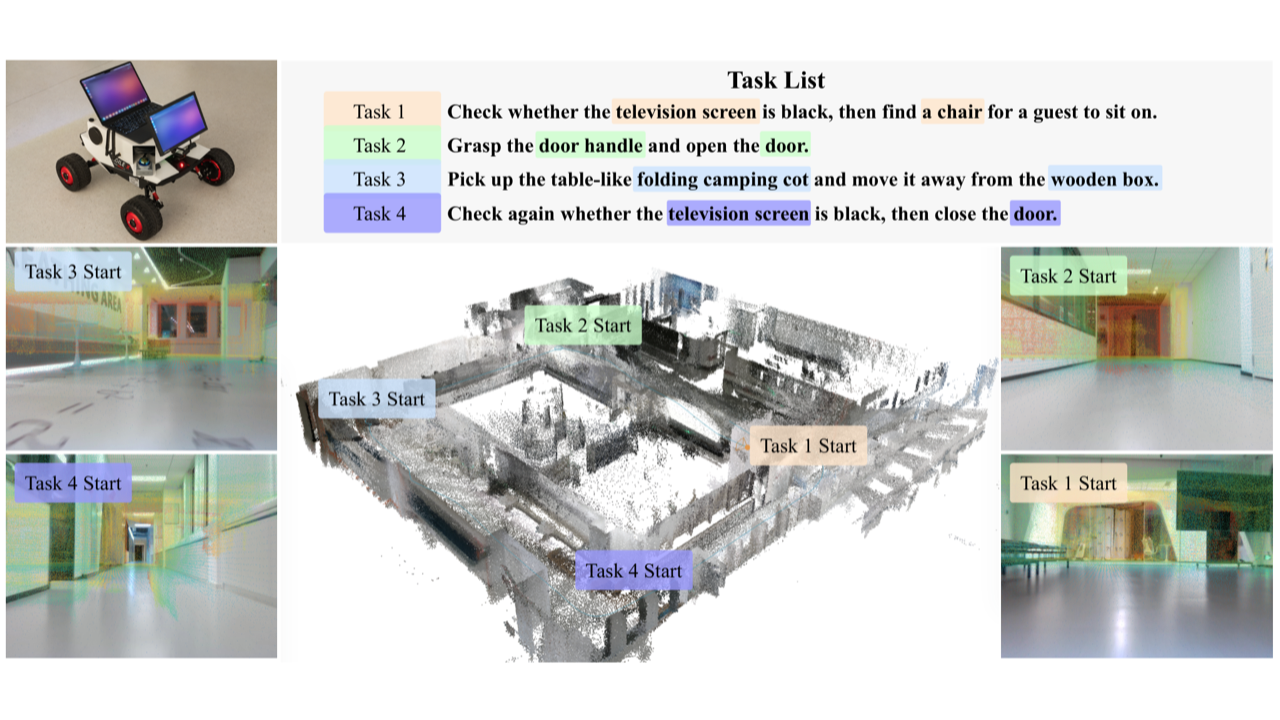
PORTER: Edge-Cloud Residency for Persistent 3D Scene Graph Memory
, , , , , , , arXiv preprint arXiv |
|
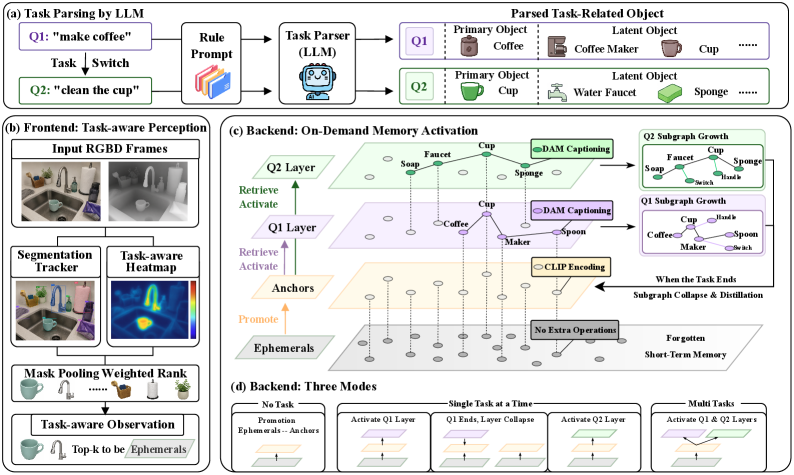
Just-In-Time Scene Graph Growth: Combating Perceptual Saturation in Long-Horizon Robotics
, , , , , , , , , arXiv preprint arXiv |
|
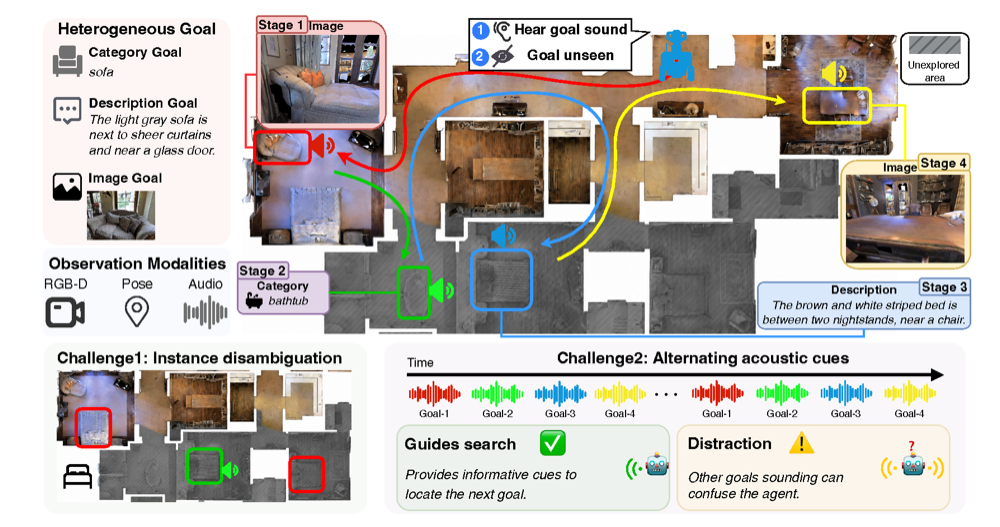
LH-AVLN: A Benchmark for Long-Horizon Audio-Visual-Language Navigation
, , , , , , arXiv preprint arXiv |
|
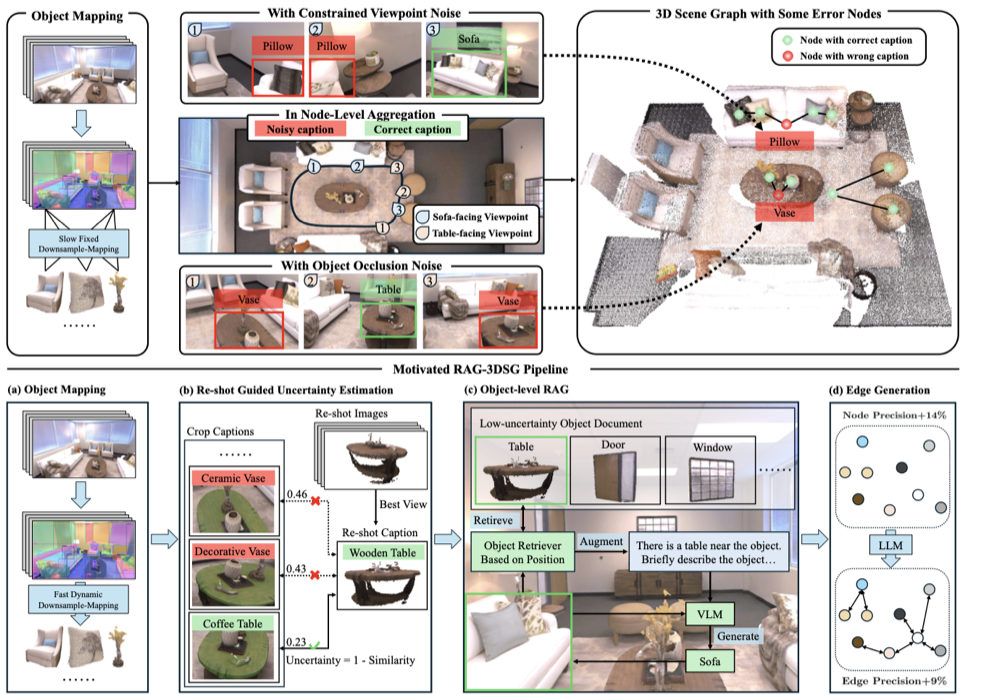
RAG-3DSG: Enhancing 3D Scene Graphs with Re-Shot Guided Retrieval-Augmented Generation
, , , , , Accepted by ECCV 2026 arXiv / Code / Video |
|
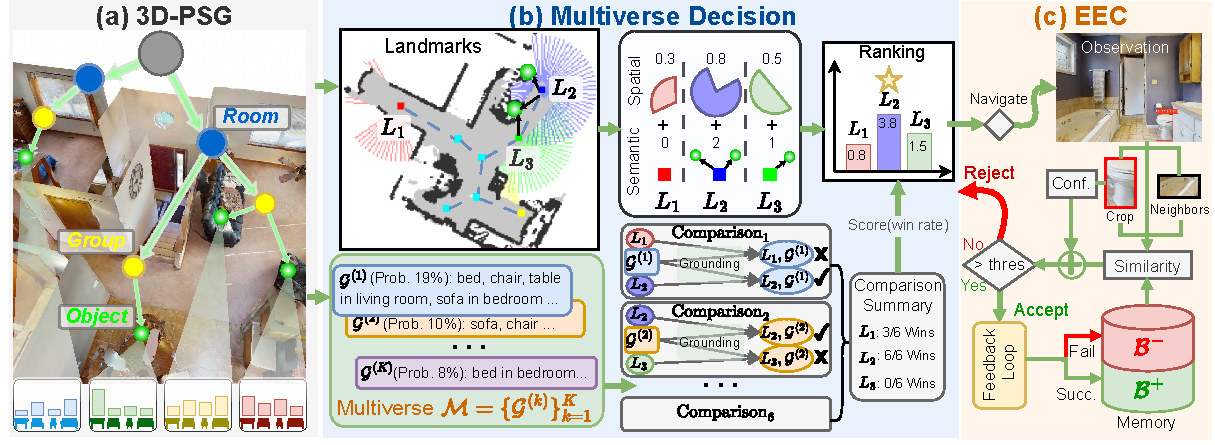
PSG-Nav: Probabilistic Scene Graph Navigation via Multiverse Decision Making
*, *, , , Accepted by ICML 2026 arXiv / Code |
|
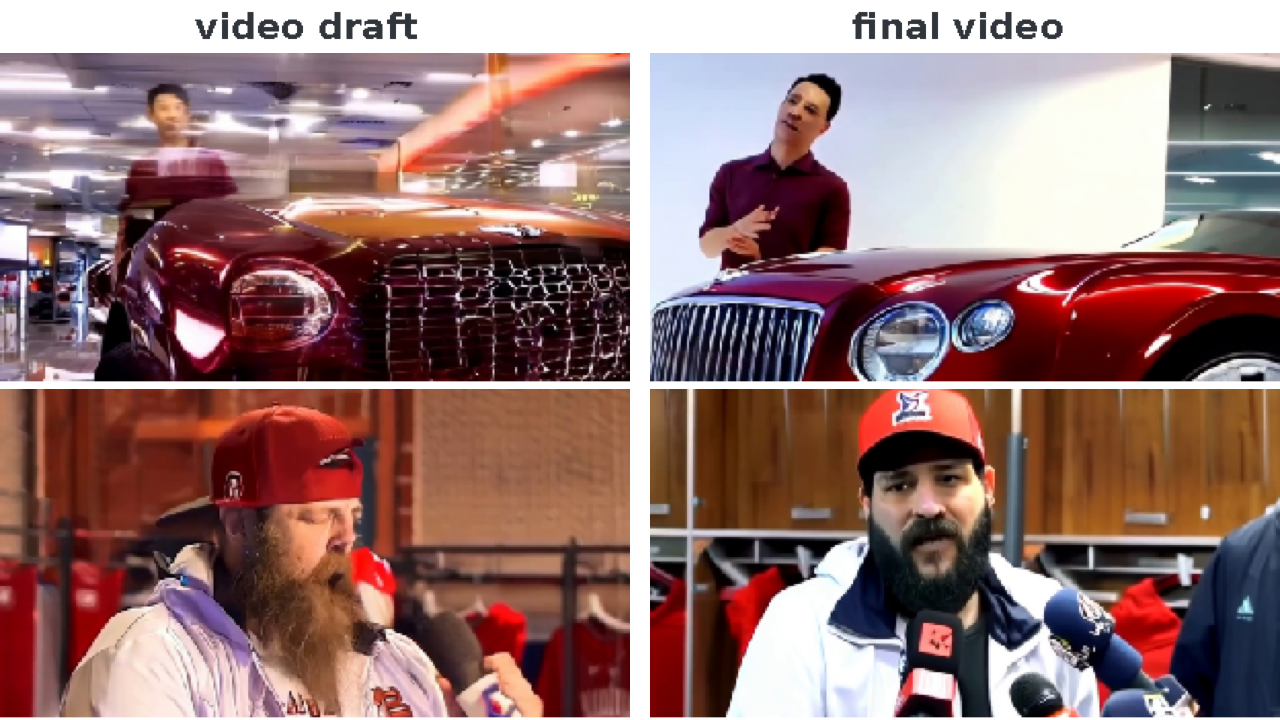
ProactGen: Learning Proactive Clarification for Video Generation
, , , , , , , arXiv preprint arXiv |
| In the Year of 2024 | |
|
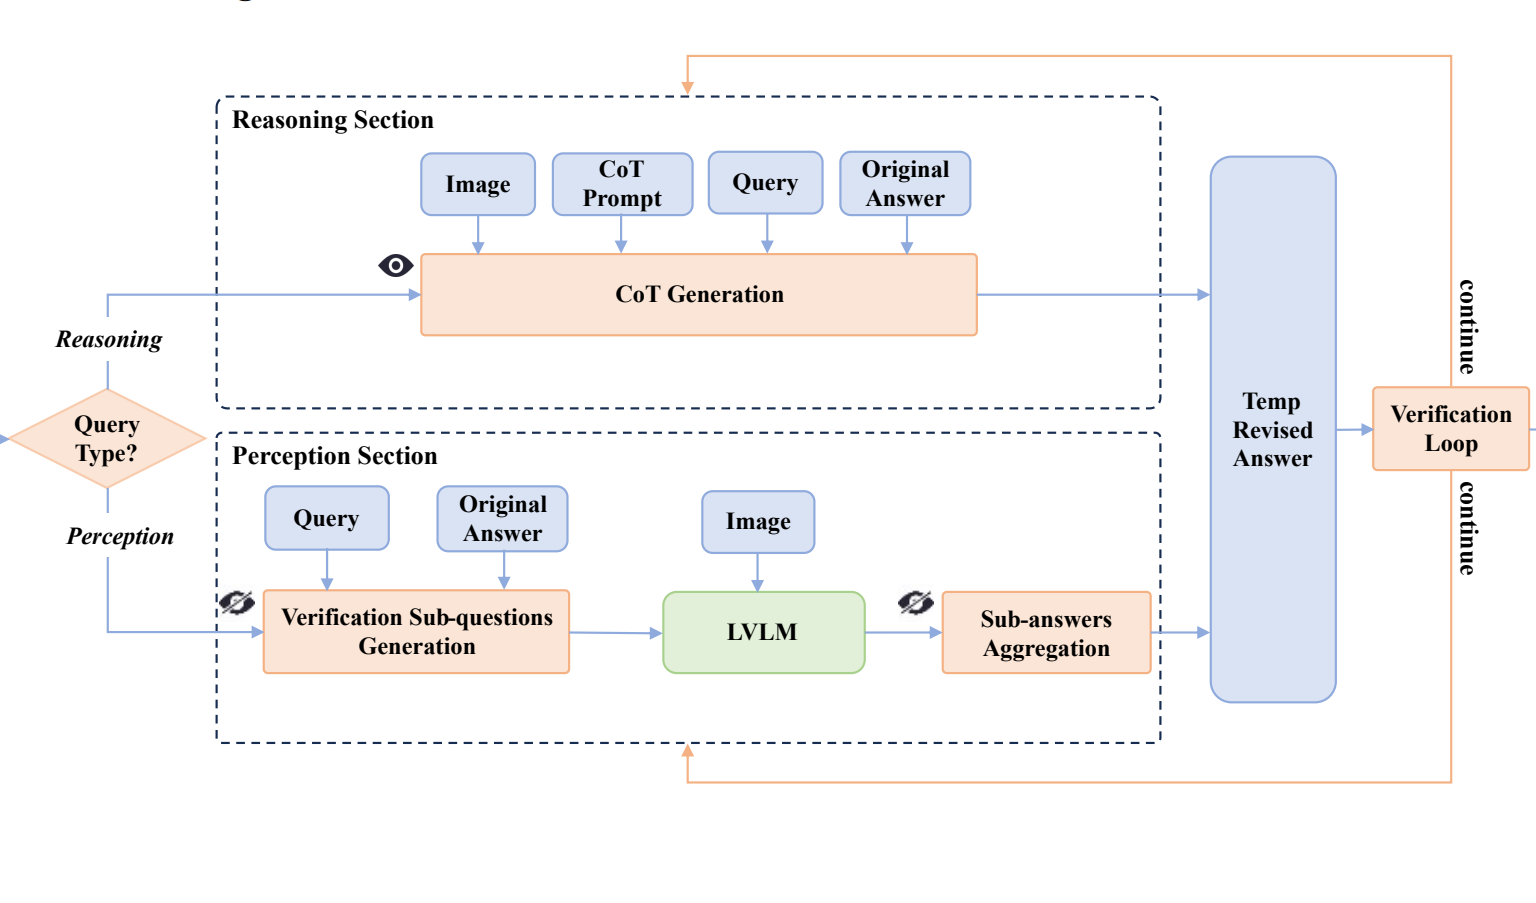
A Unified Hallucination Mitigation Framework for Large Vision-Language Models
*, *, *, Accepted by TMLR arXiv / Code |
| In the Year of 2023 | |
|
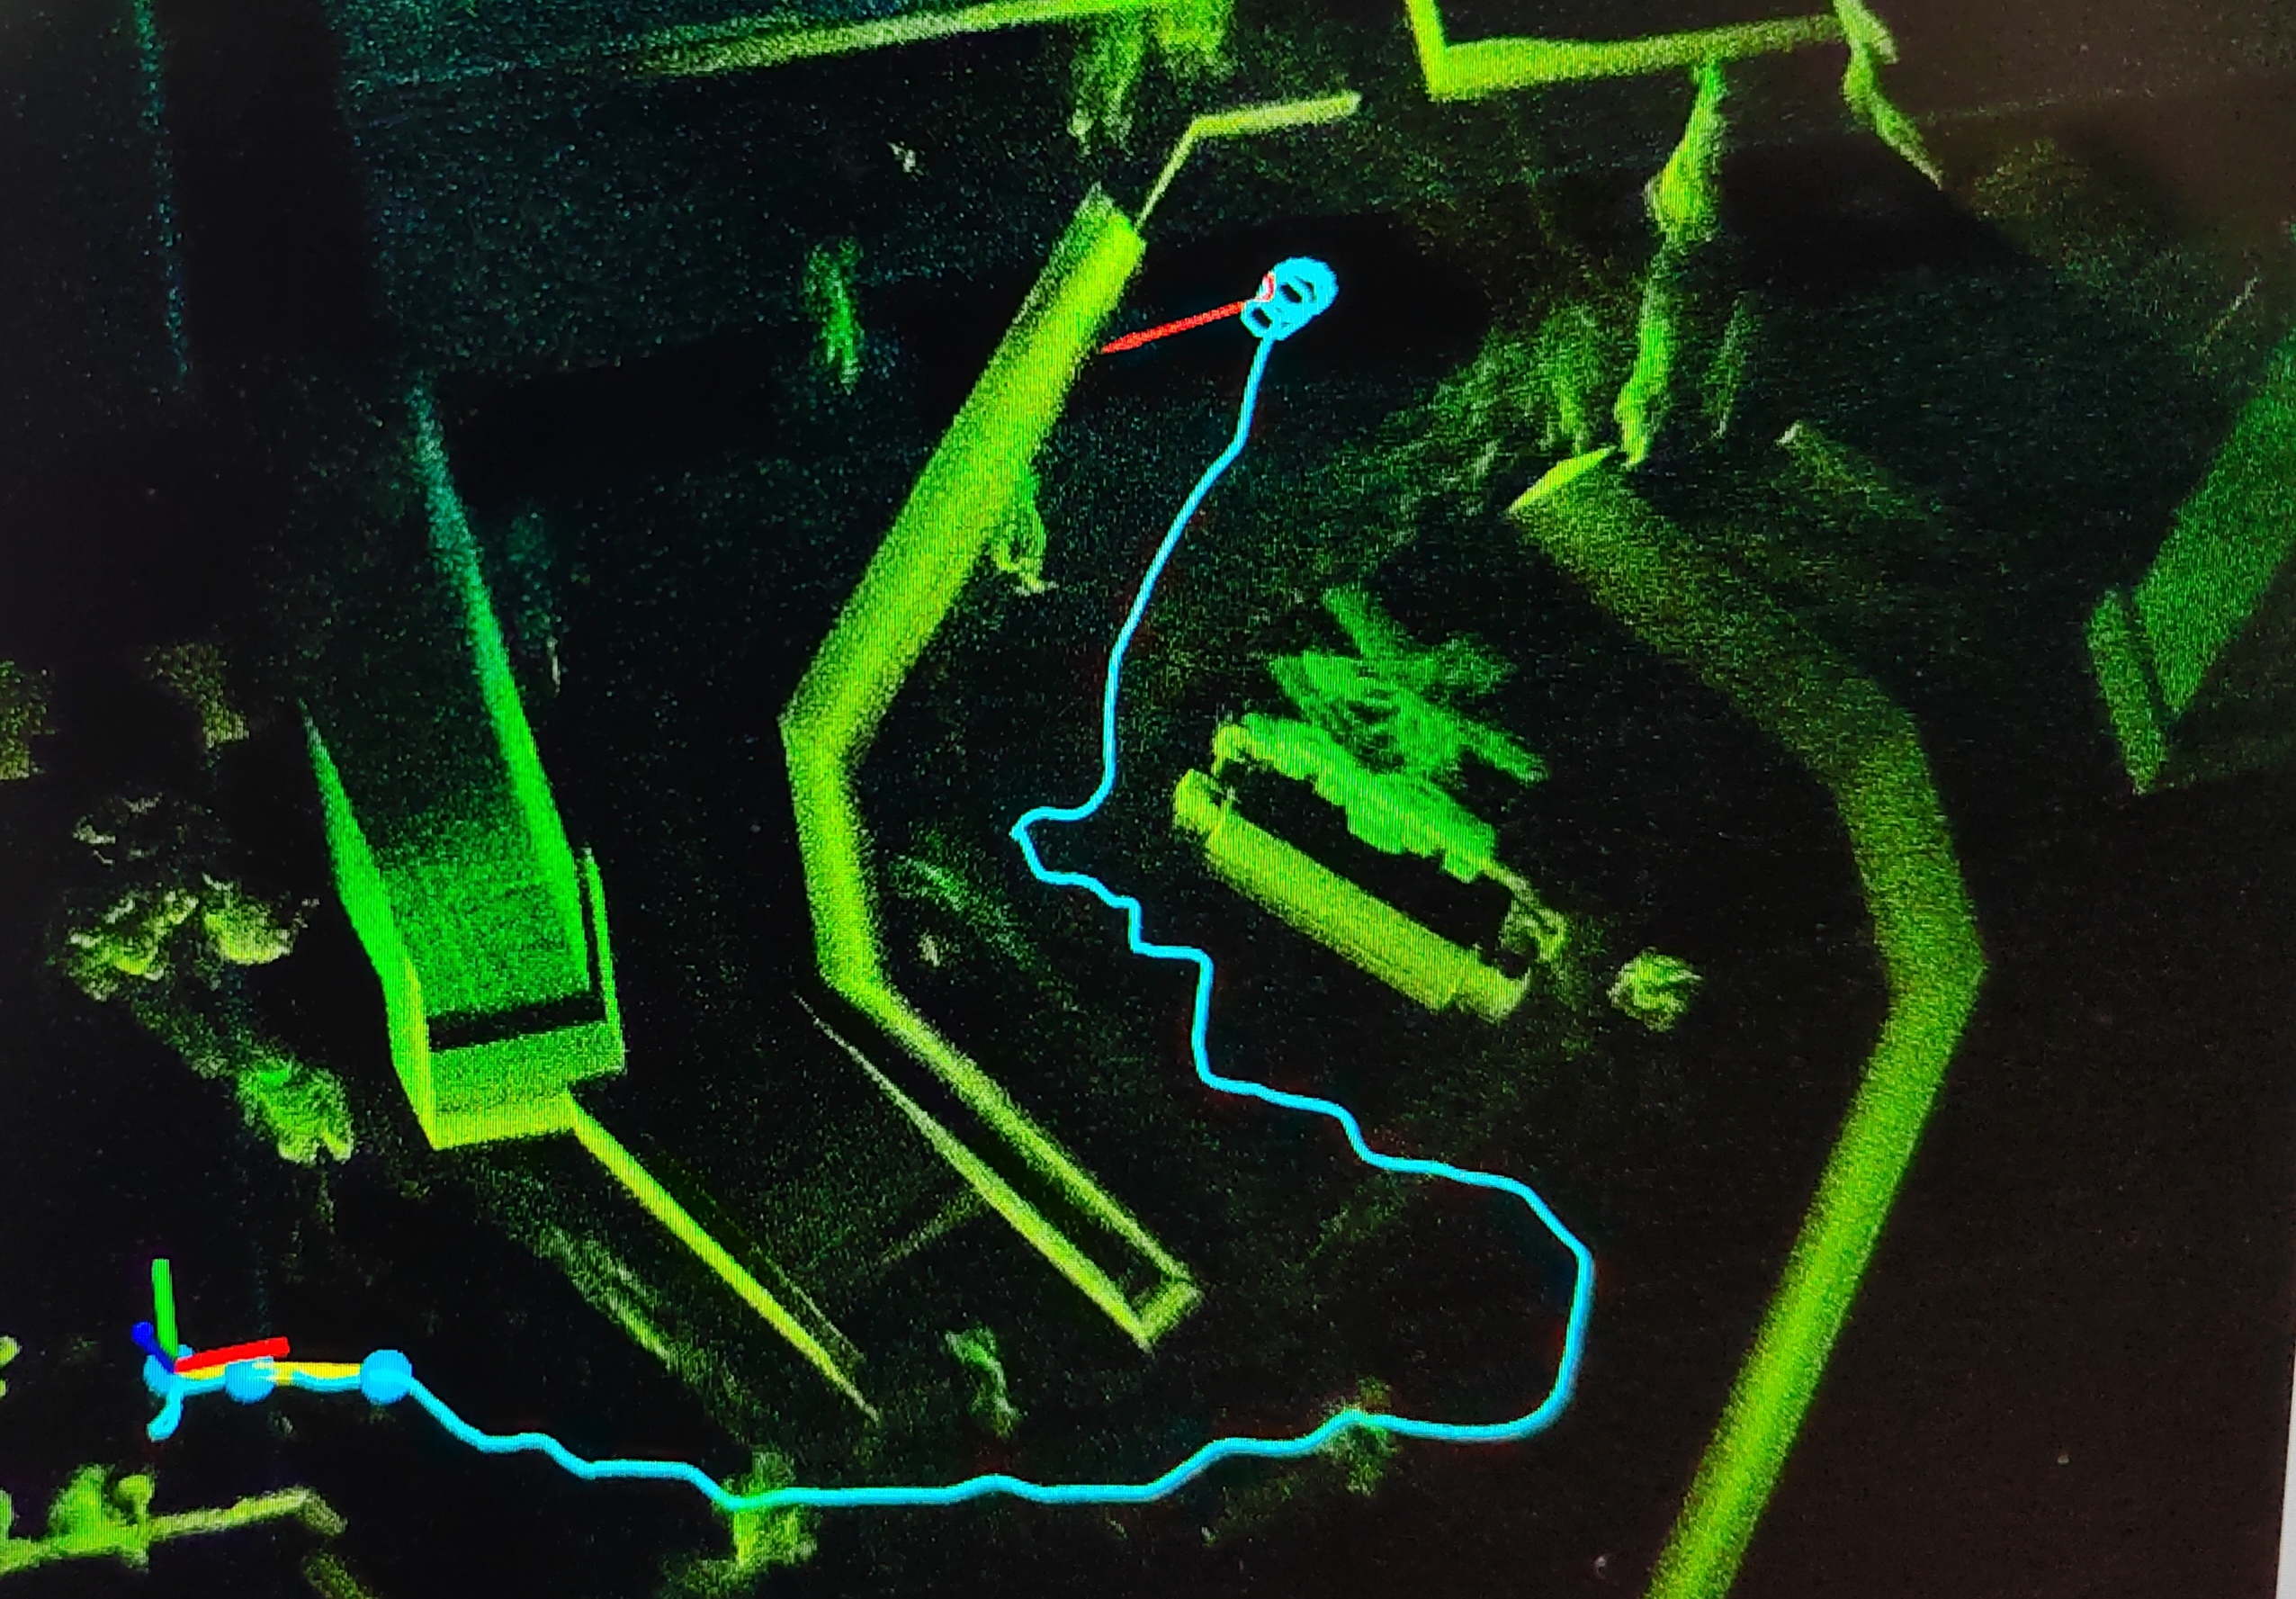
A LIO System with Front/Back-End Odometry and Loop-Detection
Used by Competition Team (Private)
A fusion odometry: It uses LIO as the front-end odometry, uses imu pre-integration to fill the frames, and uses ScanContext as the spatial descriptor for back-end loop detection.
|
Academic Service
Journal Reviewer: IEEE Transactions on Robotics (T-RO), IEEE Transactions on Image Processing (TIP).
Conference Reviewer: ICRA, ICLR, ECCV, ICML.
Award
|